Mihailo Radović
I'm an MSc student in Electrical Engineering and Computing (module: Applied Mathematics) at the University of Belgrade, School of Electrical Engineering. I also work
as a Data Engineer at Nordeus.
|
|
|
PhD search: I'm currently looking for a PhD position in generative models, world models, and robot learning. My long-term goal is to help build general-purpose autonomous agents that understand the physical world, learn from experience, and act in it safely, and I'm open to research directions that move toward that goal. If you think I'd be a good fit for your group, I'd love to hear from you by email. ResearchI'm interested in generative modeling (diffusion and flow matching), world models (JEPA), and robot learning. Most of my work is on flow matching: using continuous-time generative models both to generate images and to learn expressive, multi-modal policies for continuous control. Representative papers are highlighted. |
|
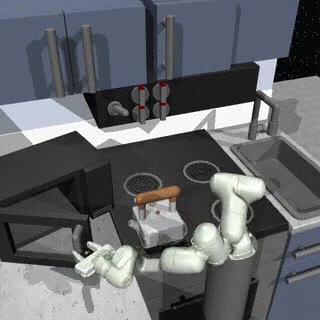
Flow Matching Policy for Behavioral Cloning
Mihailo Radović, Filip Marčić IcETRAN, 2026 paper / pdf / code Modeling a behavioral cloning policy as a continuous-time flow captures the multi-modal behavior in diverse offline datasets, matching or outperforming Gaussian and diffusion policies on standard continuous-control benchmarks. |
|
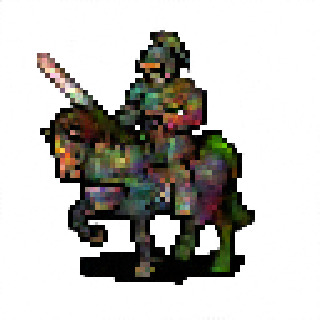
SpriteFlow: Flow-Based Pixel-Art Character Generation
Mihailo Radović Bachelor's thesis, Union University, School of Computing, 2025 Advisor: Prof. Nemanja Ilić code A flow matching model with a time-conditioned U-Net that transforms Gaussian noise into 128×128 RGBA pixel-art characters. |
Miscellanea |
Blog |
Learnings on f-divergences, 2026 All posts |
|
Built on Jon Barron's website template. |